본문 바로가기 주메뉴 바로가기

(주)엠제이비전테크

3D Bin Picking

Development background

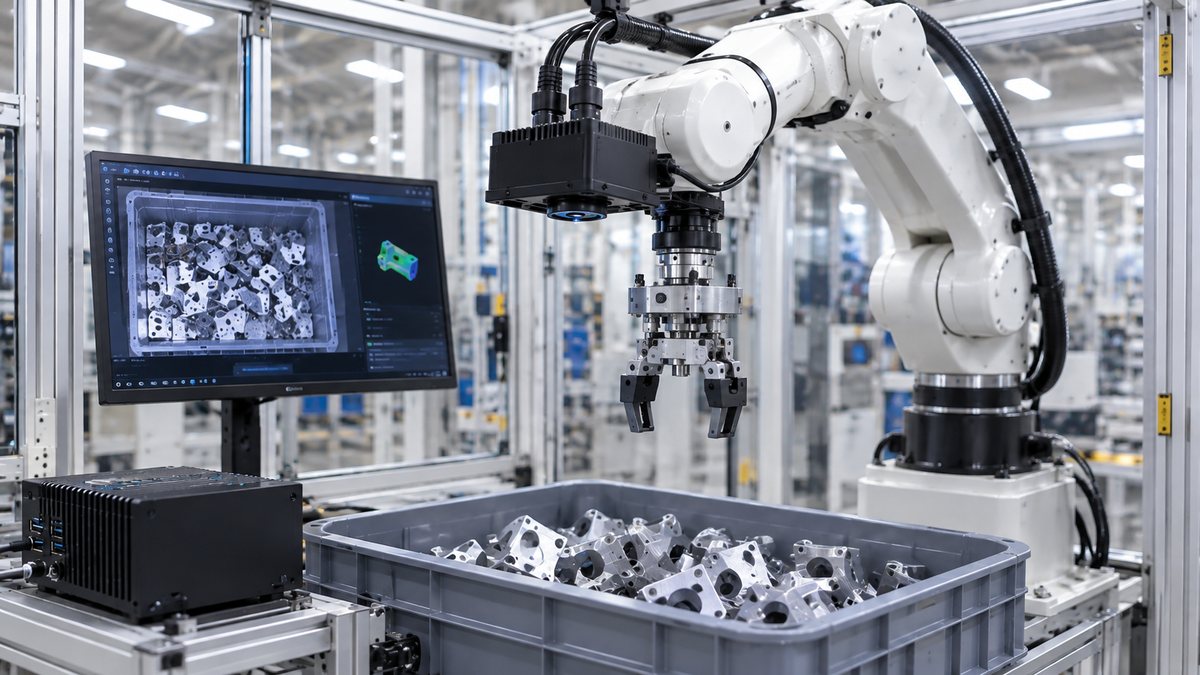
A 3D bin picking system that combines deep learning vision with 3D sensors and robot control, so robots recognize, pick and load parts supplied loose in bins without any aligning equipment

Solution

Features

Bin picking doesn't end with 3D recognition. One system turns recognition results into paths the robot can actually pick along, and also handles product changeovers and data during operation.

  • 3D Vision + Deep Learning Recognizes Even Overlapping Parts

    01

    3D Vision + Deep Learning Recognizes Even Overlapping Parts

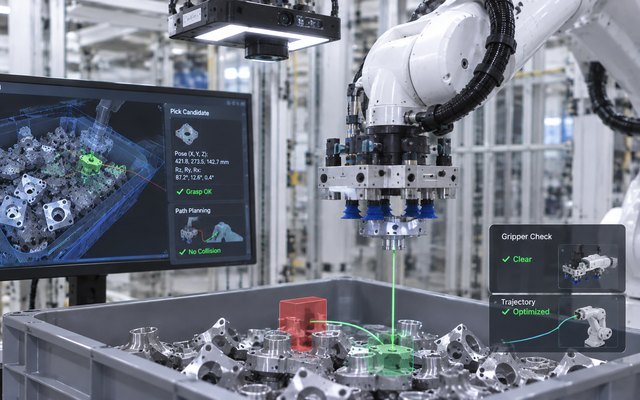
    A structured-light or stereo 3D sensor captures the whole bin at once to build a point cloud, and deep learning identifies each part and calculates its 6D pose — 3 axes of position and 3 of rotation. Overlapping, flipped and glossy metal parts are recognized reliably, and the easiest picking order is decided as well.

  • Gripper Interference Check and Automatic Path Generation

    02

    Gripper Interference Check and Automatic Path Generation

    For every recognized pose, the system first checks in virtual space whether the gripper would hit the bin wall or neighboring parts, then automatically generates robot paths only for pickable parts. Register a suction, finger or magnet gripper model and approach angles and grasp points are calculated automatically, so almost no teaching is needed.

  • Universal Robot · Equipment Integration

    03

    Universal Robot · Equipment Integration

    Connects to major industrial robots and cobots — Doosan, Hyundai, FANUC, ABB, KUKA, Yaskawa and more — through standard interfaces. The vision controller sends pick coordinates and poses to the robot controller and exchanges load-complete, bin-change and emergency-stop signals with machine tools, conveyors and PLCs via I/O or fieldbus.

  • Product Registration in a Day, Operations You Can Measure

    04

    Product Registration in a Day, Operations You Can Measure

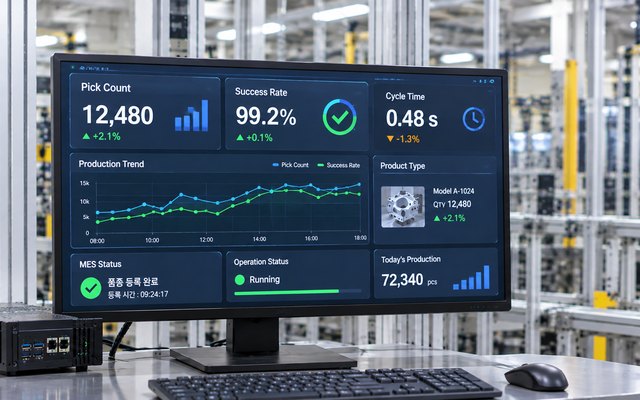
    New parts can be picked right away by importing a CAD model or training on a few sample shots, so even high-mix sites need no dedicated jigs. Pick counts, success rate, cycle time and bin-change history are recorded on the dashboard and in MES, so robot cell status can be checked at a glance.
Function

Process A single vision controller handles every step so that one cycle, from capture to loading, finishes within 3–5 seconds.

  • STEP 1

    3D Capture

    Scans the whole bin at once

    Structured lightStereoLaser lineSimultaneous 2D color

    POINT CLOUD · 0.1 s

  • STEP 2

    Recognition · Pose Estimation

    Deep learning part identification, 6D pose

    6D poseOverlapping · flippedGlossy partsPick order

    DEEP LEARNING · ±0.5 mm

  • STEP 3

    Interference Check · Path Generation

    Gripper collision check, robot path

    Wall · part interferenceAuto grasp pointApproach anglePath optimization

    COLLISION FREE PATH

  • STEP 4

    Picking · Loading

    Places onto jigs, conveyors or pallets

    Aligned placementEmpty bin detectionRetryResult logging

    PLACE · 3~5 s / EA

System Configuration The vision controller sits between the sensor and robot and handles recognition, path planning and integration. The standard setup simply adds a sensor and controller to your existing robot.

  • 3D Sensor Selection

    Structured-light, stereo or laser-line sensors chosen to suit parts and bins, including glossy metal.

    OUT · POINT CLOUD

  • Deep Learning Part Recognition

    Identifies overlapping and flipped parts and calculates 6D poses with confidence scores.

    OUT · 6D POSE / SCORE

  • Interference Check · Path Generation

    Automatically generates collision-free grasp points and approach paths from the gripper model.

    OUT · GRASP / PATH

  • Product Registration · Recipes

    Registers products from CAD or sample training and saves gripper, bin and placement positions as recipes.

    OUT · RECIPE

  • Robot · PLC Integration

    Integrates with major robot brands and cobots, PLCs and machine tools via I/O and fieldbus.

    OUT · ROBOT I/F · DIO

  • Operating Statistics · MES

    Records pick counts, success rate, cycle time and bin-change history, integrated with MES.

    OUT · MES / DASHBOARD

Applications and Benefits

Applications and Benefits
Process Target Parts Sensor · Gripper Features Cycle (Example)
Machine tending Machined metal parts, cast/forged blanks Structured light / laser · finger gripper Glossy metalMachine loadingCNC integration 4~6 s
Assembly line feeding Automotive parts, molded parts, small metal parts Structured light · suction / finger High-mixAligned placementOrientation check 3~5 s
Depalletizing Boxes, sacks, totes Stereo (large FOV) · suction Mixed boxesLayer recognitionLogistics integration 6~10 s
Box · tote picking Items in logistics totes, part kits Structured light + 2D color · suction SKU identificationKittingWMS integration 3~5 s
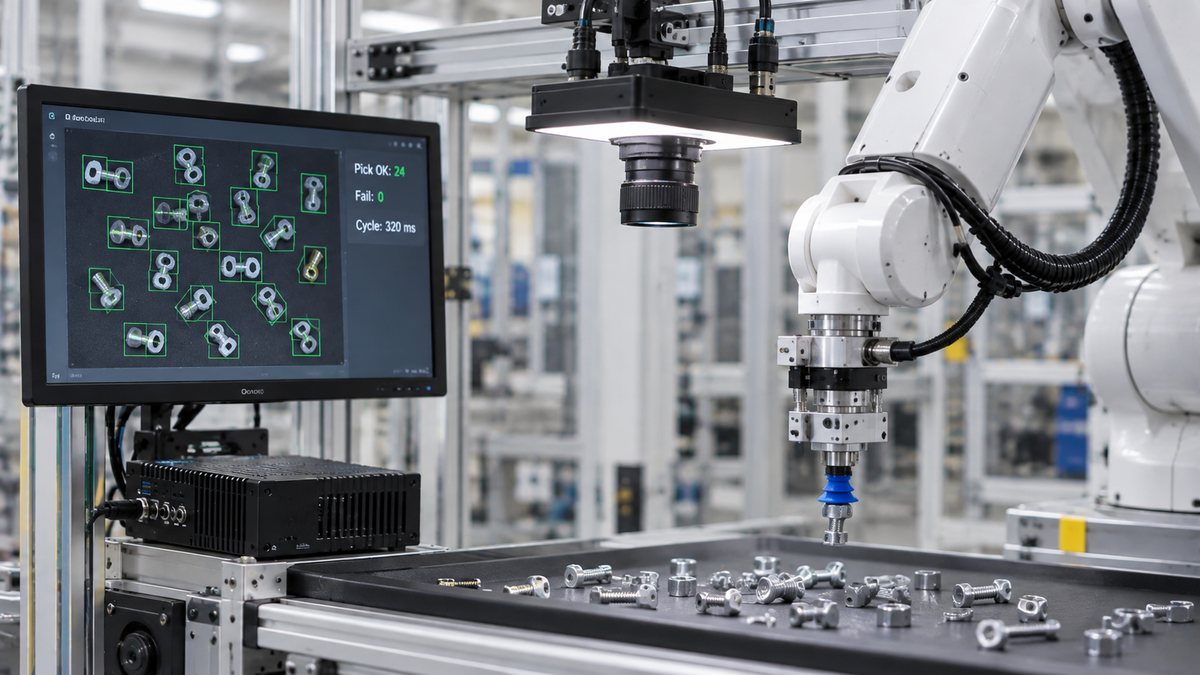
2D picking (flat) Small parts on conveyors or trays, bolts · nuts 2D camera + lighting · suction / magnet Deep learning position · orientationLow costHigh speed 1~2 s

Product Lineup

  • 3D Bin Picking Vision PackageADD-ON PACKAGE

    3D Bin Picking Vision Package

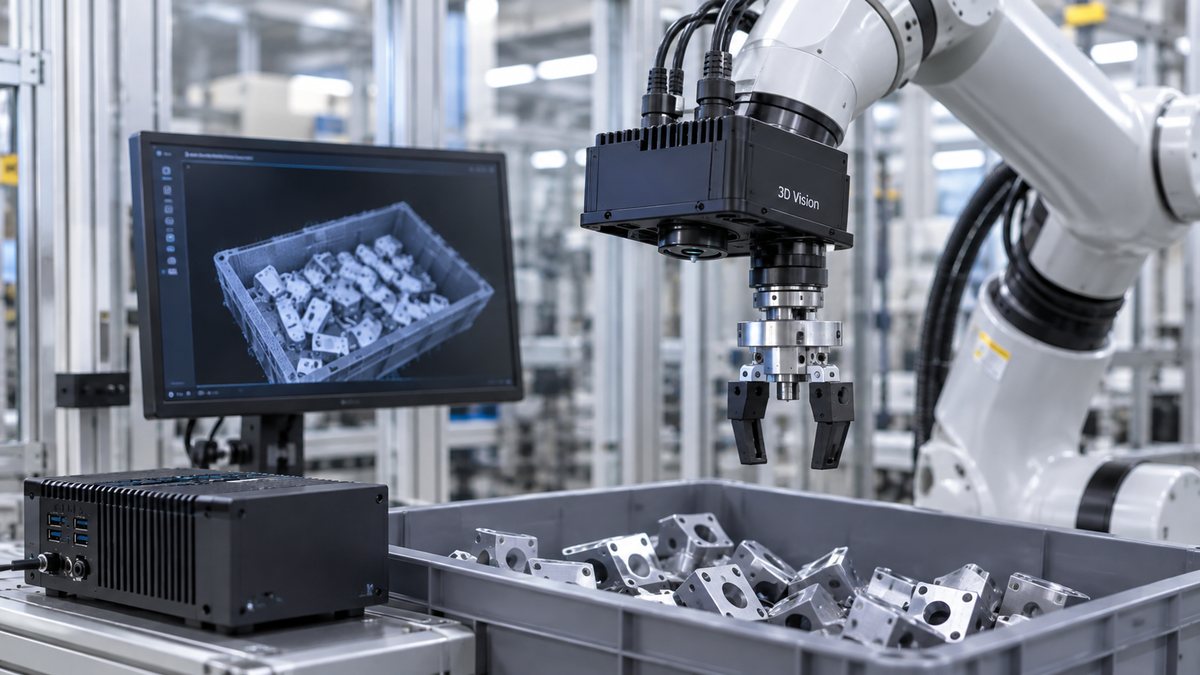
    Our base product adds a 3D sensor, vision controller and bin picking software to your existing robot. Because the robot and gripper stay as they are and only vision is added, it has the lowest cost and shortest lead time.

    Composition
    1 set of 3D sensor, vision controller (GPU), bin picking SW, robot interface
    Target
    Machining and assembly lines with robots already installed
  • Bin Picking Robot Cell (Turnkey)TURNKEY CELL

    Bin Picking Robot Cell (Turnkey)

    Robot, gripper, 3D vision, bin station and safety fencing supplied as one cell. A turnkey package including installation, teaching and commissioning, ideal for sites introducing robot automation for the first time.

    Composition
    Industrial robot or cobot, gripper, 3D vision package, 2-bin station, safety devices
    Target
    Machine tending, assembly line part feeding
    Option
    Tool changer, jig alignment station, post-loading inspection camera
  • Depalletizing · Box Picking SystemLOGISTICS

    Depalletizing · Box Picking System

    A configuration for logistics sites. A large-FOV stereo sensor recognizes mixed boxes on pallets layer by layer and a suction gripper unloads them. For picking items from totes, a 2D color camera is added to identify SKUs.

    Composition
    Stereo 3D sensor (large FOV), vision controller, suction gripper, conveyor integration
    Target
    Distribution center inbound/outbound, factory material warehouses
    Option
    2D color camera, barcode reader, WMS integration
  • 2D Deep Learning Picking SystemENTRY · 2D

    2D Deep Learning Picking System

    An entry-level product that picks small parts laid in a single layer on conveyors or trays, using a 2D camera and deep learning to recognize position and orientation. With no 3D sensor and the same camera and lighting as our automotive parts inspection, it is the most economical option.

    Composition
    2D camera, lighting, vision controller, suction / magnet gripper
    Target
    Bolts and nuts, small molded parts, electronic component feeding
    Option
    Feeding conveyor, post-loading pass/fail inspection
상단으로